Summary
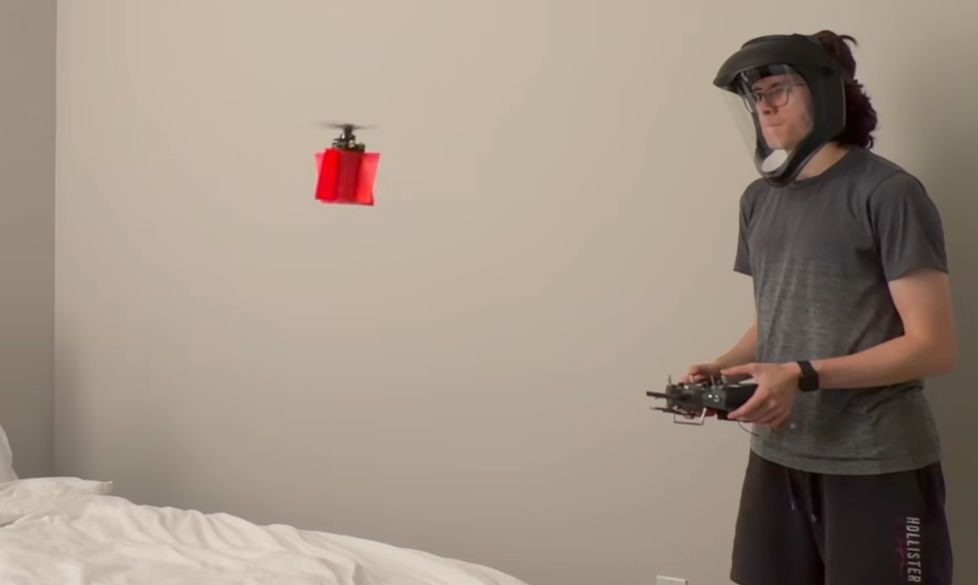
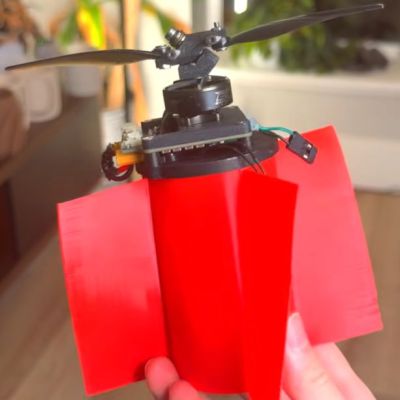 There are of course a number of ways to make a drone fly with a single helicopter, but the compromise usually is to use very large propellers, as well as other mechanisms that make for a very large drone. This wasn’t good enough for [Joshua Bird] who wanted to have a very small, single propeller drone.
Key to making it work is not only a very high RPM, but also a hinged propeller hub that manipulates the angle of the blades in such a way that both pitch and roll can be controlled if you react quickly enough. This turned out to be impossible using standard motor ESCs that do not directly measure the motor’s speed and position but rely on back EMF.
In the final prototype of the drone such details had to be measured directly, with super-fast adjustments to the motor’s speed only possible with custom controller code and a lot of trial and error. Even then the drone would often lose track of its position and crash once more. The solution there was to add an infrared beacon in the room and a sensor on the drone, to give it a fixed reference point.
You can find the project files so far on the GitHub project page, with upcoming changes to the drone design involving improvements like adding a scanner to the drone so that it can autonomously use features in its environment as fixed reference points. That way it might conceivably be able to fly outside as well, which would be quite exciting to see.
Please be kind and respectful to help make the comments section excellent. (Comment Policy)